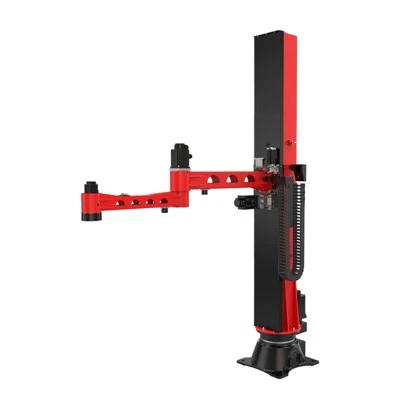
If you’ve ever stood on the floor of a high-volume consumer electronics factory, watching a 500-ton injection molding robot snare a perfectly formed smartphone case out of a mold in 2.2 seconds, you’ve probably wondered exactly how that “end-of-arm tooling” (EOAT)—the custom-designed gizmo gripping the part—pulls off such a precise, repeatable move. As a supplier of injection molding robots, I get asked this question at least once a week, usually from plant managers who’ve dealt with the nightmare of a part scrapped because a gripper misaligned by half a millimeter, or from quality engineers who can’t wrap their heads around why a $200,000 molding machine is undermined by a $2,000 tool. The answer isn’t a single number, and it’s not as simple as “it’s accurate to 0.1mm”—but I’ve spent 12 years working with EOAT for injection molding, and I can break it down in plain talk. Injection Molding Robot
First, let’s define what we’re actually measuring here, because that’s where a lot of confusion starts. When you talk about EOAT accuracy in injection molding, you’re not just measuring how well it moves from point A to point B on the robot’s path. You’re measuring two distinct things: repeatability and absolute positioning accuracy. Repeatability is the tool’s ability to move to the same point over and over again, the exact same way, every single cycle. Absolute positioning accuracy is how close that point is to the “true” position the robot’s controller has programmed it to hit. In injection molding, 9 times out of 10, repeatability is far more important than absolute accuracy. A part that’s molded consistently won’t care if the gripper is 0.05mm off from the theoretical mold’s takeout point—so long as it’s 0.05mm off in the same direction, every single time. That’s why even lower-cost EOAT for high-speed applications hits repeatability numbers most people would never guess are possible.
Let’s start with the repeatability side, because that’s where our team’s experience is most concrete. For standard, production-grade EOAT that we ship to automotive parts plants, medical device manufacturers, and consumer goods factories, the typical repeatability is between ±0.02mm and ±0.1mm. Wait, that’s a huge range, right? The difference between a toy factory molding plastic cups and a medical factory molding insulin pen components is night and day, and that range reflects that. Let’s narrow it down: for high-volume, commodity parts (like plastic bottle caps, disposable cutlery, or simple toy components), we often specify EOAT with ±0.08mm repeatability. That’s more than enough to grab a part from a mold that’s machined to ±0.1mm—hardly perfect, but for 10,000 parts a day, it’s completely reliable. For precision parts, though, the ones where a 0.03mm misalignment means a part gets rejected (we’re talking catheter connectors, smartphone camera bezels, or aerospace fasteners), we can build EOAT with repeatability as tight as ±0.015mm. I’ve personally watched our tooling grab a micro-component 10,000 cycles in a row, and the variance in position was less than the thickness of a human hair. That’s not hype—that’s what the math and the sensor data tell us.
Now, the absolute positioning accuracy part, which is where a lot of external factors get involved, because EOAT doesn’t exist in a vacuum. If you were testing a gripper in a lab, on a granite surface plate, you might get absolute accuracy as good as ±0.05mm, but in a real factory, that number almost always goes up. Why? Let’s list the culprits: first, the robot itself. Every injection molding robot has its own positioning accuracy, and EOAT is mounted on the end of that arm, so it inherits any errors from the arm’s joints, drives, and controller. A 500-ton molding robot might have a positioning accuracy of ±0.2mm over its full travel, and if the EOAT isn’t properly calibrated, that error stacks on top of the tool’s own accuracy. Second, thermal expansion. Factory floors aren’t temperature-controlled, right? On a hot summer day, a steel gripper can expand by 0.01mm for every meter of length. That’s a tiny number, but if your gripper is 2 meters long, that’s a 0.02mm shift, enough to throw off a tight tolerance. Third, part and mold condition. Molded parts shrink, sometimes unevenly, and mold surfaces wear over tens of thousands of cycles. If the part you’re grabbing shifts 0.05mm in the mold between cycles, your EOAT has to adjust to that, which means its absolute accuracy is less important than its ability to adapt.
This is where a common mistake happens for new customers: they come to us asking for “EOAT with 0.01mm accuracy,” assuming that’s the number they need, only to realize that their mold and robot can’t even deliver consistency that tight. Last year, a customer from a medical device startup called us because their old tooling was scrapping 15% of parts, and they blamed the EOAT. When we audited their system, we found their mold was wearing 0.08mm every 10,000 cycles, so even if the EOAT was accurate to 0.01mm, the part it was grabbing shifted more than that from cycle to cycle. We recalibrated their EOAT to prioritize repeatability over absolute accuracy, adjusted their mold maintenance schedule, and their scrap rate dropped to 1.2%. That’s the thing about EOAT accuracy: it’s not a standalone spec—it’s a piece of the whole system, and you have to size it to the application, not the other way around.
Let’s talk about how EOAT accuracy is measured, because a lot of suppliers will throw around numbers without explaining how they arrived at them. The standard test for EOAT repeatability is ISO 9283, a global standard for robot performance that’s used in manufacturing across the board. We test every custom EOAT we build to ISO 9283, using a laser measurement system that tracks the tool’s position over 1,000 consecutive cycles. For precision EOAT, we use a coordinate measuring machine (CMM) too, to check how the gripper jaws align relative to each other, not just their position in space. A lot of cheap EOAT from overseas doesn’t use these tests—they’ll quote a “0.02mm accuracy” based on the specs of the components they use, not real-world testing. We’ve seen that: a client brought in a competitor’s EOAT that was advertised as ±0.02mm repeatability, but when we tested it, it was ±0.11mm, because their assembly was sloppy and the drive belts stretched over a few thousand cycles. That’s why working with a supplier that tests their tooling under real production conditions is non-negotiable.
There’s also the myth that pneumatic grippers are less accurate than electric grippers. I get this all the time. It’s true that pneumatic grippers have more compliance—they move a little when they grip a part, because air pressure isn’t as rigid as a motor-driven system. But modern pneumatic EOAT, with closed-loop pressure control and precision-machined jaws, can hit the same repeatability as basic electric grippers, around ±0.03mm, for a third of the cost. For high-speed applications where cycle time is king, pneumatic is often better, and I’ve seen it work for 100 million cycles without losing accuracy. The advantage of electric grippers comes in when you need to grip delicate parts, or adjust grip force dynamically, like when you’re handling a thin plastic film part that would crumple if you squeeze too hard. Electric grippers can control force to within 0.1N, which lets them adapt to part variations while still maintaining tight positioning accuracy.
Now, let’s talk about edge cases, because those are where accuracy really matters. For companies molding parts for electronics assembly, like connectors that get inserted into motherboards, the EOAT has to not just grab the part, but align it to within ±0.02mm so it fits into a socket without breaking. A few years ago, we worked with a semiconductor manufacturer that needed to handle lead frames, which are strips of metal with tiny pins that hold integrated circuits. Their EOAT had to pick a lead frame pin, lift it 10mm, and place it into a carrier with ±0.01mm accuracy—no exceptions. We built a custom EOAT with linear encoders on each gripper jaw, calibrated to their specific robot and mold, and it ran 24/7 for 18 months without a single misaligned part. That’s the level of accuracy that’s possible when you tailor the tooling to the application.
What about common mistakes that hurt accuracy? A lot of customers cut corners during installation: they mount EOAT by hand, use cheap fasteners that stretch, or don’t calibrate the tool after changing molds. I’ve seen a factory that tried to swap molds without recalibrating their EOAT, and within 500 cycles, they were scrapping 20% of parts because the gripper was 0.15mm off. The fix? A 10-minute calibration step that uses the robot’s vision system to confirm the gripper’s position, and they never had that problem again. Another mistake is overspeeding. If you run the robot faster than its rated cycle speed, the arm flexes, and that flex transfers to the EOAT, causing inaccuracies. We always tell customers to test their EOAT at their actual production speed, not just the maximum speed the robot can hit. Flex from rapid movement can add 0.1mm or more to the error, even in precision tooling.
So, to circle back to the original question: what’s the accuracy of end-of-arm tooling on an injection molding robot? The short answer is, it depends. For most production applications, that number is somewhere between ±0.02mm and ±0.1mm for repeatability, with absolute accuracy ranging from ±0.05mm to ±0.2mm in real factories. For ultra-precision applications, it can get as tight as ±0.01mm repeatability. But the real takeaway is that accuracy isn’t the only number that matters—consistency, reliability, and alignment with your entire molding system are far more important. A tool that’s accurate to 0.01mm but breaks every 10,000 cycles is useless, just like a tool that’s cheap but scraps half your parts is a bad investment.
If you’re looking to upgrade your injection molding EOAT, or you’re dealing with scrap rates that you can’t trace back to the robot or mold, we can help. Our team works with factories of all sizes, from small consumer goods shops to large medical device manufacturers, to design, test, and install EOAT that’s tailored to your exact production needs. No generic quotes, no one-size-fits-all specs—just tooling that delivers the accuracy you need, without the hidden costs of mismatched systems or poor installation. Reach out to our team to learn more about how we can optimize your injection molding process and cut down on part waste.
Industrial Robot References
- ISO 9283:1998, Manipulating industrial robots – Performance criteria and related test methods. International Organization for Standardization, Geneva, Switzerland.
- Groover, M. P. (2019). Automation, Production Systems, and Computer-Integrated Manufacturing, 5th edition. Pearson Education, Inc.
- International Moldmakers Association (IMA). (2021). EOAT Best Practices for Injection Molding Applications. IMA Technical Report Series, No. 17-01.
- Robotics Industries Association (RIA). (2020). End-of-Arm Tooling Performance Standards for Industrial Robots. RIA Standard RIA TR R15.606-2020.
Robotic Technology (GD) Co., Ltd.
Robotic Technology (GD) Co., Ltd. is one of the most experienced injection molding robot manufacturers and suppliers in China, also supports custom service and one year warranty. Please feel free to wholesale CE approved injection molding robot for sale here from our factory. Contact us for quotation.
Address: Room 102, No. 30,Hengfeng 2nd Road,Daguo, Changping Town, Dongguan City,Guangdong,China
E-mail: admin@iroboticplus.com
WebSite: https://www.rb-tic.com/
